Hey, I'm Michelle!
I'm a senior at MIT studying EECS (6-2) and robotics. I'm broadly interested in building robots that learn to interact with and adapt to their environment and the humans in it. I'm advised by Pulkit Agrawal and collaborate with Andreea Bobu. In summer 2026, I was an Atlas AI Research intern at Boston Dynamics.
Outside of research, I develop assistive tech with and for co-designers with the Assistive Technology Club. I also concentrate in leadership and negotiation through the Department of Urban Planning. I love any adventure, particularly those found outdoors or in the pages of a book.
I am applying for PhD programs starting Fall 2027!
Updates
- Oct. 2026 We released Compliant-GMT. Make your humanoid compliant while doing anything!
- Oct. 2026 Payload-Aware Compliant Teleoperation for Humanoids (PATCH) to appear at Humanoids 2026
- July 2026 CSAIL Media highlighted SoftMimic in a new video
- June 2026 Started research internship at Boston Dynamics on the Manipulation RL team
- June 2026 Presented SoftMimic at ICRA 2026
Research
I work on giving robots physical common sense as we know it. Currently I'm interested in how we can combine priors from human data with reinforcement learning to enable efficient, robust robot behaviors that still make sense to us. I'm excited by the new opportunities for manipulation and physical human-robot interaction that arise when our robots have physical common sense.
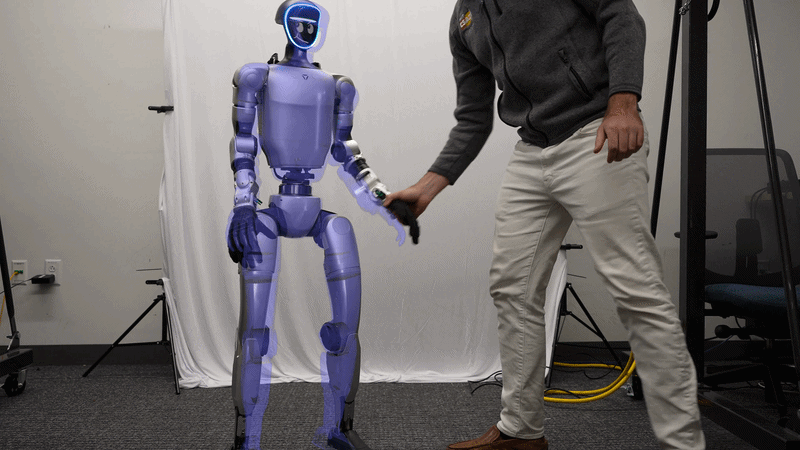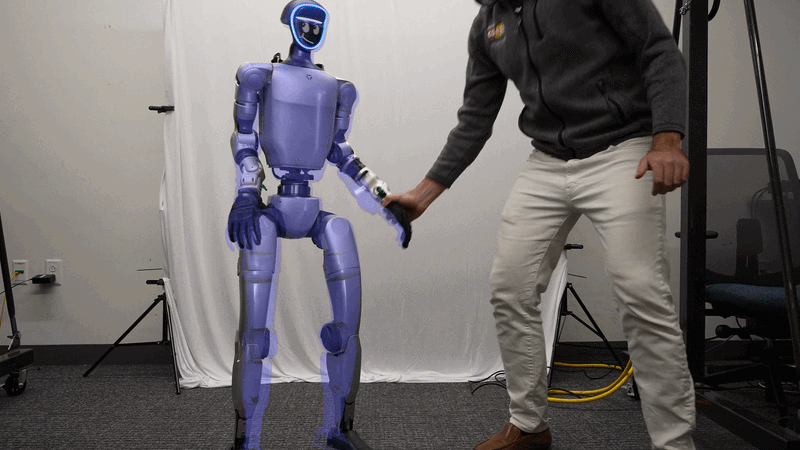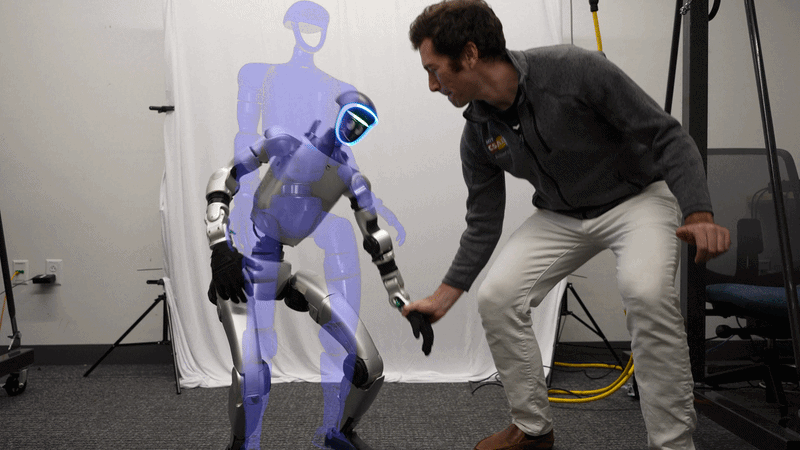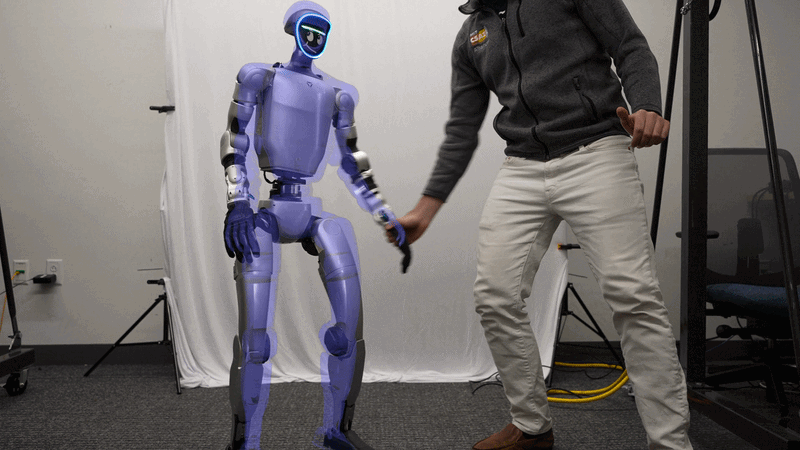
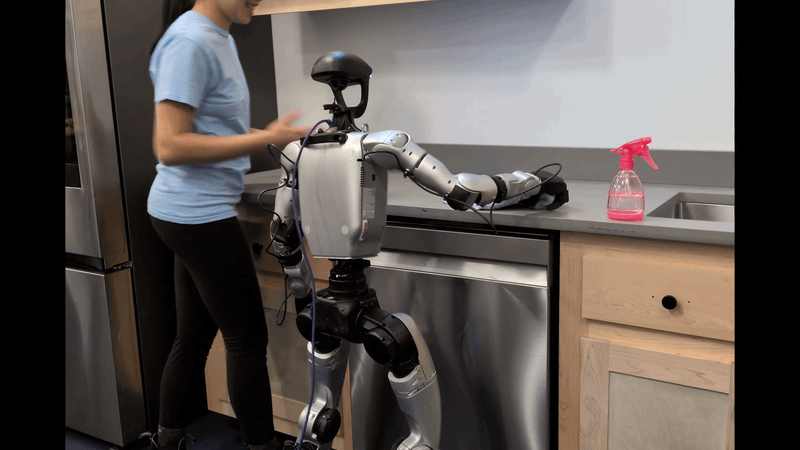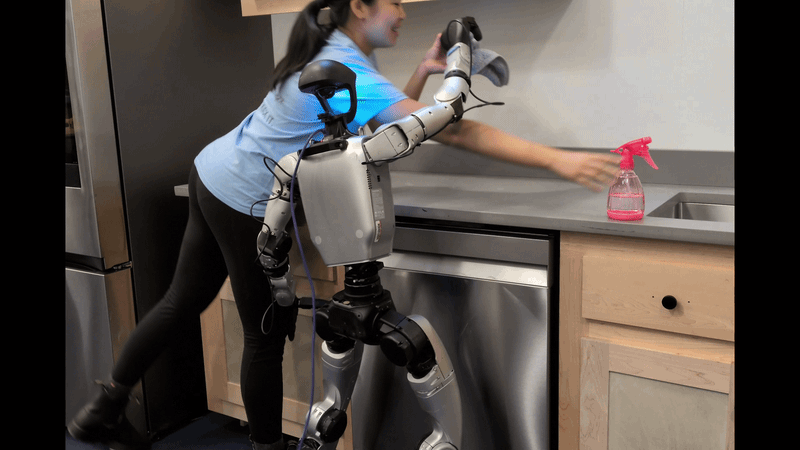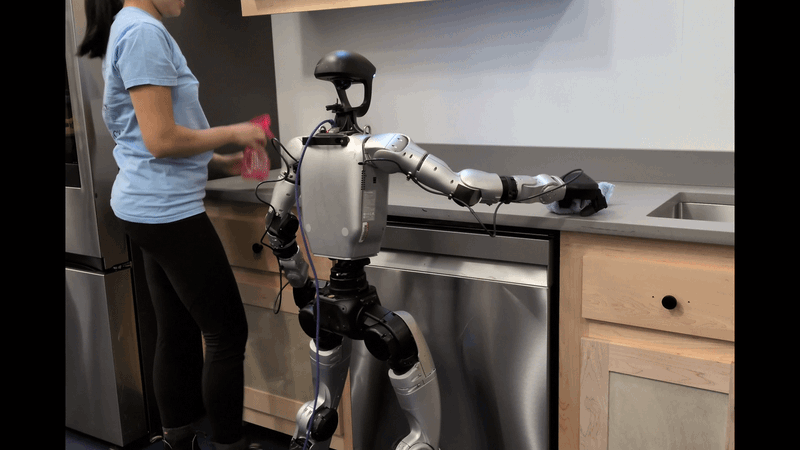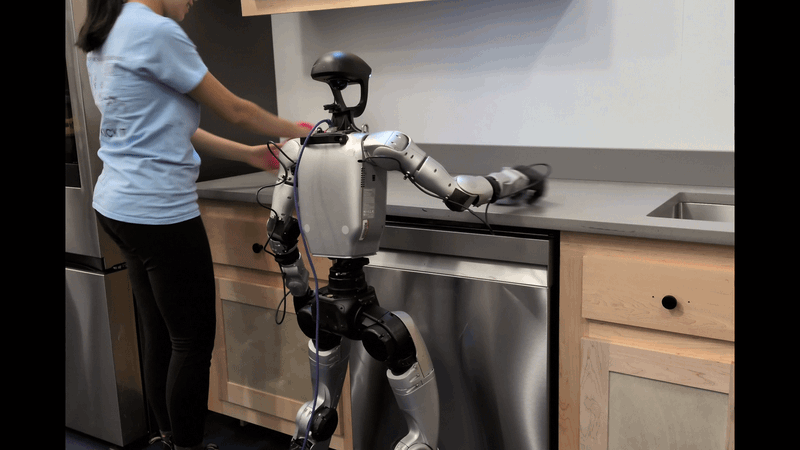
SoftMimic: Learning Compliant Whole-body Control from Examples
Gabe Margolis*, Michelle Wang*, Nolan Fey, Pulkit Agrawal · ICRA 2026
We introduce a RL-based framework to learn compliant whole-body control policies for humanoid robots from synthetic examples, enabling safe, disturbance-tolerant behavior and task generalization.
Compliant-GMT: Making General Motion Tracking Compliant via Residual Reference Adaptation
Venki Parsuram, Michelle Wang, Pulkit Agrawal · Under Review
We introduce C-GMT which achieves both whole-body compliance and generality by leveraging a pretrained GMT for motion tracking while introducing compliance with a propioception-conditioned residual adapter.
Learning to Look Around: Enhancing Teleoperation and Learning with a Human-like Actuated Neck
Bipasha Sen, Michelle Wang, Nandini Thakur, Aditya Agarwal, Pulkit Agrawal · CORL 2024 WBCM Workshop Spotlight
We introduce a bimanual teleoperation system with a 5-DOF actuated neck that enables natural perception behaviors, improving teleoperation performance and imitation learning.